




When it comes to designing modern robots, various researchers are all trying to solve pretty much the same problem: how to make robots that can reach places difficult for humans to access. They’ve come up with robots that can swim underwater, crawl through rubble, and land on tree branches like birds.
But every existing type of robot has its own limitations. Wheeled and legged robots struggle with uneven terrain, and can be stopped by something as simple as a set of stairs. Flying drones don’t care about ground conditions, but they can’t carry too much weight. There’s clearly room for something that combines the advantages of both.
And this is exactly what the Hopcopter is designed to do. It was developed by researchers from City University of Hong Kong and The Hong Kong University of Science and Technology. Essentially, it’s a quadcopter drone with a single spring-loaded leg that it can hop on, as you can guess from the robot’s name.

The idea was inspired by birds, which often hop from place to place instead of constantly flying, saving them a lot of energy. Similarly, the Hopcopter can hop from one spot to another without wasting its battery, but it can also continuously stay in the air like a regular drone when there is no suitable place to land. By switching between flying and hopping, the robot could reach places that would only be accessible by airdrop otherwise.
During the hop, the robot enters a free-fall state, and then, as it goes up, its four rotors engage very briefly. According to the creators, this allows the Hopcopter to cover quite long distances while using just one-tenth the energy of a drone the same size.
This is actually the second version of the Hopcopter. The original prototype, announced two years ago, could successfully land on its single leg on flat surfaces like concrete or fine gravel and push off to get to the next spot. But once the terrain became less predictable, it struggled quite a bit: it would sink into sand, slip on ice, and often fall over when trying to land on sloped surfaces.
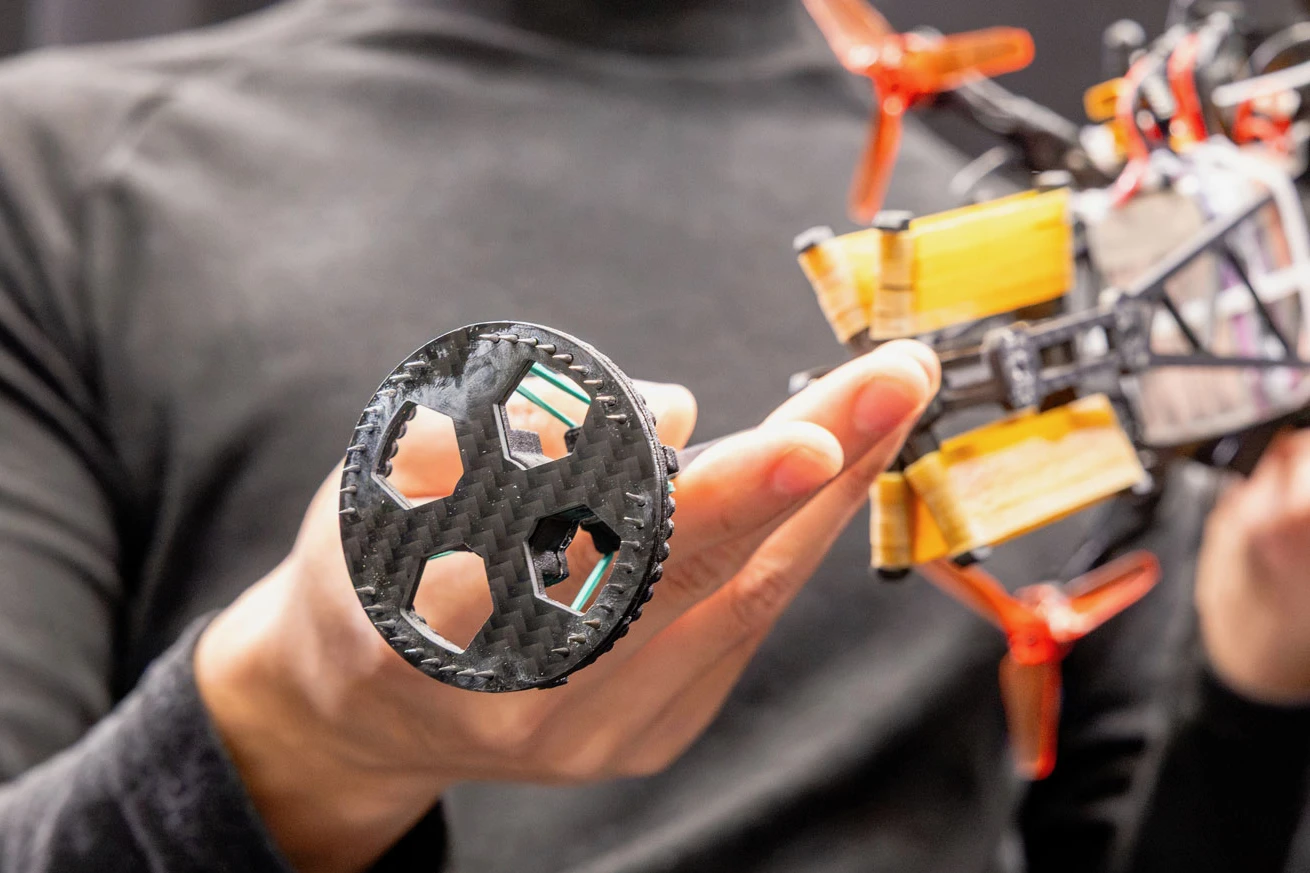
To overcome these limitations, research partners at the University of Toronto came up with a new flexible foot pad that helps the robot land on different types of terrain. Its clever design has a few useful features to tackle all the possible challenges.

First, it has a wider surface, which helps distribute the robot’s weight more evenly and prevents it from sinking into soft soil or sand. It also features three rubber bands that provide enough tension to bring the foot back into position after landing, helping the robot regain its balance.
Finally, the bottom of the foot pad is covered with short spikes that help it grip slippery surfaces.
These changes made a pretty significant difference. The new foot pad reduced performance variation across different terrains by 84%. In simple terms, the robot can now land much more consistently when moving between complex surfaces such as ice, sand, and rocks.
Some of the creators behind Hopcopter are currently working on commercializing the technology. The production version isn't available for sale just yet, but you can find more information and technical details on the company website. They are also planning to develop a version of Hopcopter with integrated AI modules to improve obstacle avoidance.

In the future, the research team hopes to use the Hopcopter’s abilities for search-and-rescue operations, inspections of remote mining sites, and possibly even exploring other planets.
A paper on the study was recently published in the journal Advanced Intelligent Systems.
Source: University of Toronto


